
Open GNSS Processing
In the Drone Collab toolbar group, click the second icon: GNSS Tools, shown with a survey tripod. Open New Processing.
Prepare the base with Static
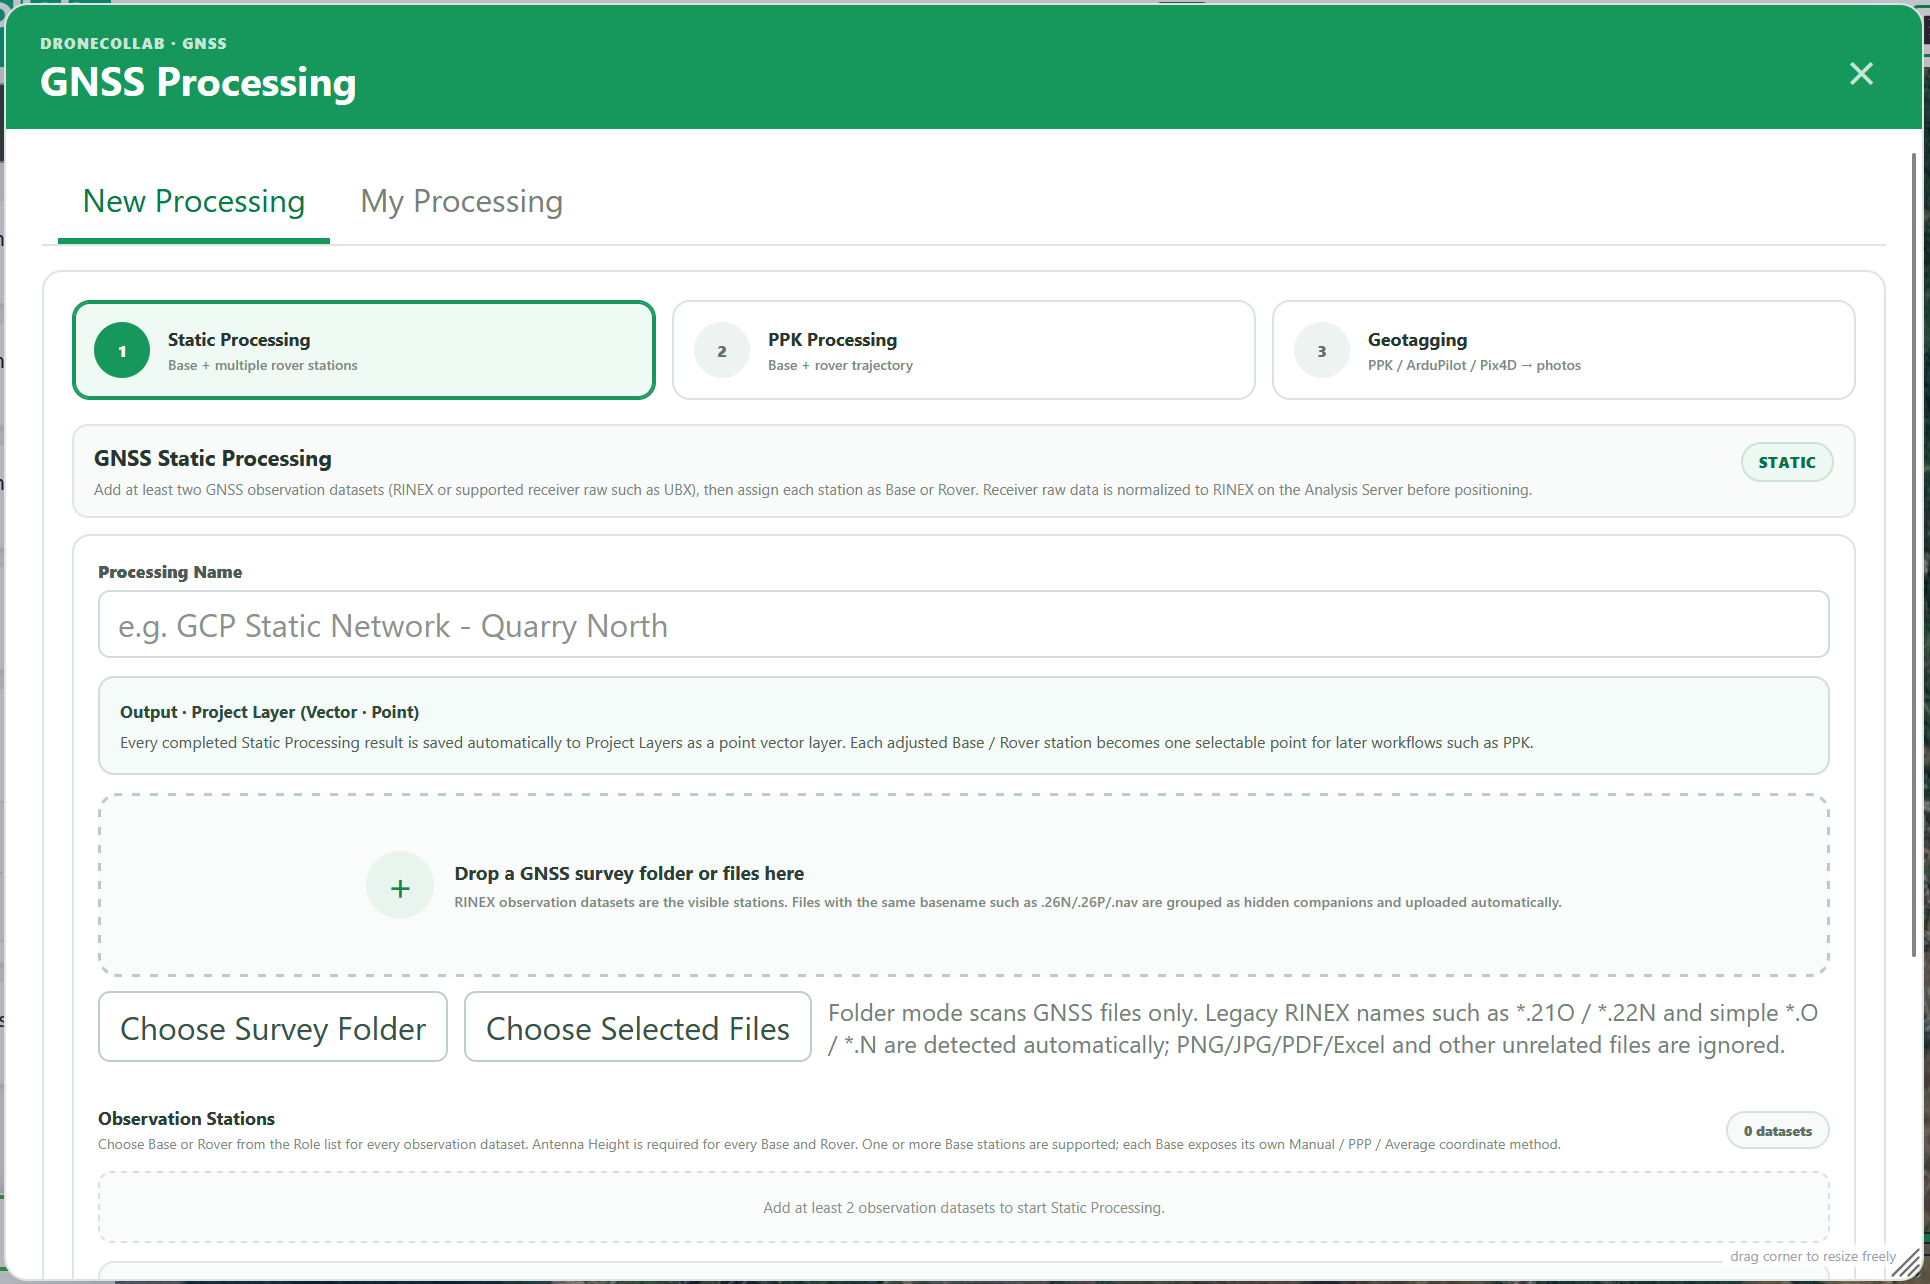
Upload at least two station observations. Assign at least one Base and one Rover, enter every antenna height and configure each Base coordinate. Click Process Static; follow My Processing and inspect the resulting Point layer.
Full form: fields, choices and explanations
Labels match the DroneCollab form. Defaults are starting settings; change them to suit the observations. Static is optional when an independently verified base coordinate is already available.
Static Processing · Observation Stations
Give each job a recognizable name. Upload RINEX observations or supported receiver raw such as UBX. Static needs Base and Rover observations; PPK needs one Base and at least one Rover. Check that observation times overlap.
| Field | Default / choices |
|---|---|
| Processing Name | GCP Static Network - Quarry North (example) |
| Choose Selected Files / Choose Survey Folder | RINEX OBS / supported receiver raw; ≥ 2 stations |
| Role | Base / Rover; ≥ 1 of each |
Static Processing · Base coordinate
Choose a verified Manual coordinate, PPP, or Average Single. PPP depends on observations and available products; Average Single is a standalone estimate, not a surveyed control point. Manual X/Y are longitude/latitude in decimal degrees, with ground ellipsoidal height in metres; convert projected coordinates first. Use a decimal point for coordinates.
| Field | Default / choices |
|---|---|
| Base coordinate | Manual coordinate (known) / Determine with PPP / Average Single |
| Latitude / Y · Longitude / X · Ground h / Z | WGS84 decimal degrees · ground ellipsoidal height (m) |
Static Processing · Antenna Height (m)
Measure vertically from the survey mark to the antenna reference point (ARP), for every Static station and the PPK Base. Range: 0–100 m; 1,800 and 1.800 both mean 1.8 m. Enter ground height separately: the solver applies antenna height, so do not add it twice.
| Field | Default / choices |
|---|---|
| Antenna Height (m) | Required for every Base and Rover; 0–100 m |
Static Processing · Processing settings
Static Solution Mode chooses independent baselines or weighted multi-base network adjustment; Auto selects the workflow. Scientific Strategy tests bounded profiles. For a moving drone choose Kinematic; Static is for a stationary receiver. PPK Auto Optimize compares alternative profiles when the initial quality is weak; Standard uses one profile.
| Field | Default / choices |
|---|---|
| Solution Mode | Auto (default) / Independent Base → Rover baselines / Multi-base Network · weighted least squares |
| Scientific Strategy | Auto Scientific (default) / Single RTKLIB profile |
| Process Static | My Processing → completed Project Layer (Vector · Point) |
Correct the flight with PPK
Select PPK Processing. Upload the Base observation, choose its coordinate and antenna height, then add the drone Rover observations. Review PPK configuration and click Process PPK.

Full form: fields, choices and explanations
PPK Processing · Base / Rover
Give each job a recognizable name. Upload RINEX observations or supported receiver raw such as UBX. Static needs Base and Rover observations; PPK needs one Base and at least one Rover. Check that observation times overlap.
| Field | Default / choices |
|---|---|
| Processing Name | Flight 01 PPK (example) |
| Base Observation / Raw | One Base observation / supported raw |
| Rover / Drone Observation | One or more Rover observations; companion NAV separated automatically |
PPK Processing · Base Coordinate
Choose a verified Manual coordinate, PPP, or Average Single. PPP depends on observations and available products; Average Single is a standalone estimate, not a surveyed control point. Manual X/Y are longitude/latitude in decimal degrees, with ground ellipsoidal height in metres; convert projected coordinates first. Use a decimal point for coordinates.
| Field | Default / choices |
|---|---|
| Base Coordinate | Project Point Layer (default) / Manual Known Coordinate / Determine with PPP / Average Single |
| Latitude / Y · Longitude / X · Ground Ellipsoidal Height / Z | Manual Known only; decimal degrees and ground ellipsoidal height (m) |
PPK Processing · Antenna Height (m)
Measure vertically from the survey mark to the antenna reference point (ARP), for every Static station and the PPK Base. Range: 0–100 m; 1,800 and 1.800 both mean 1.8 m. Enter ground height separately: the solver applies antenna height, so do not add it twice.
| Field | Default / choices |
|---|---|
| Antenna Height (m) | Required; vertical ground → ARP, 0–100 m |
PPK Processing · Project Point Layer
Project Point Layer reads X/Y from the selected point. Select the actual Base Point and a ground ellipsoidal Z field, preferably ellipsoidal_height_m. Auto detection does not verify the height datum. Manual Z appears only after selecting Manual value; use it if no suitable field exists.
| Field | Default / choices |
|---|---|
| Point Layer | Point layer in active project, including completed Static results |
| Base Point | The actual reference station in that layer |
| Z Field | Detected numeric property / Geometry Z / layer API Z / Manual value |
| Manual Z Value (m) | Only when Z Field = Manual value; ground ellipsoidal height |
PPK Processing · PPK configuration
Static Solution Mode chooses independent baselines or weighted multi-base network adjustment; Auto selects the workflow. Scientific Strategy tests bounded profiles. For a moving drone choose Kinematic; Static is for a stationary receiver. PPK Auto Optimize compares alternative profiles when the initial quality is weak; Standard uses one profile.
| Field | Default / choices |
|---|---|
| Positioning Mode | Kinematic (default) / Static |
| PPK Solver Strategy | Auto Optimize (default) / Standard RTKLIB |
| Process PPK | My Processing → completed outputs |
Static / PPK · Satellite Selection & Frequency
Auto detects common constellations and frequencies. Manual uses the checked GPS, Galileo, BeiDou, GLONASS and QZSS systems. Select only signals recorded by both Base and Rover; choosing L1+L2+L5 does not create missing observations.
| Field | Default / choices |
|---|---|
| Satellite Selection | Automatic (default) / Manual constellation selection |
| GNSS Constellations | GPS / Galileo / BeiDou / GLONASS / QZSS; all checked initially; Manual only |
| Frequency | Auto (default) / L1 only / L1+L2 / L1+L2+L5 |
Static / PPK · Elevation & Ambiguity
Elevation Mask excludes satellites below the chosen angle. Ambiguity Resolution controls integer ambiguity solving. AR Ratio Threshold is the ambiguity validation ratio, not a precision in metres; default 3.0, permitted 1.5–10. Keep Auto unless you have a reason to choose a specific profile.
| Field | Default / choices |
|---|---|
| Elevation Mask | 10° / 15° (default) / 20° |
| Ambiguity Resolution | Auto (default) / Fix-and-Hold / Continuous |
| AR Ratio Threshold | 3.0 (default); min 1.5, max 10, step 0.1 |
Static / PPK · Ionosphere & Troposphere
Ionosphere and Troposphere control atmospheric modelling. Auto selects the implemented model; Broadcast, Estimate, Iono-free and Off are available as listed. Iono-free needs suitable multi-frequency observations. Turning a model off removes that correction.
| Field | Default / choices |
|---|---|
| Ionosphere | Auto (default) / Broadcast model / Estimate / Iono-free combination / Off |
| Troposphere | Auto · Saastamoinen (default) / Saastamoinen / Estimate / Off |
Static / PPK · Navigation & Ephemeris
Navigation may be supplied as companion NAV or generated from raw data; processing still needs usable navigation. SP3/CLK are precise products, not Rover observations. Choose Precise only with suitable products; use Raw → RINEX or the vendor converter if receiver raw cannot be identified.
| Field | Default / choices |
|---|---|
| Ephemeris | Auto · precise when available (default) / Broadcast / Precise SP3 / CLK |
| Navigation / Precise Products (Static) · Navigation / Ephemeris (PPK) | Companion RINEX NAV / generated navigation; optional SP3/CLK products |
Static / PPK · Vertical Height
Vertical Height selects the output geoid model. Default EGM2008 2.5′; other listed resolutions are alternatives. GNSS solves ellipsoidal h first, then H = h − N when the geoid is available. Verify the vertical-conversion status and retain ellipsoidal height for Base input.
| Field | Default / choices |
|---|---|
| Vertical Height | EGM2008 2.5′ (default) / EGM2008 1′ / EGM96 5′ / EGM96 15′ / EGM84 15′ |
Static / PPK · Precision Acceptance (m)
Precision Acceptance defaults to 0.10 m (range 0.01–1.00 m) and flags estimated 3-D sigma. It is not guaranteed field accuracy and does not convert FLOAT to FIX; RTKLIB FIX remains q=1. Check the report, FIX rate and warnings. Full trajectory epochs differ from camera-trigger EventPost positions.
| Field | Default / choices |
|---|---|
| Precision Acceptance (m) | 0.10 (default); min 0.01, max 1.00, step 0.01 |
Inspect trajectory and EventPost
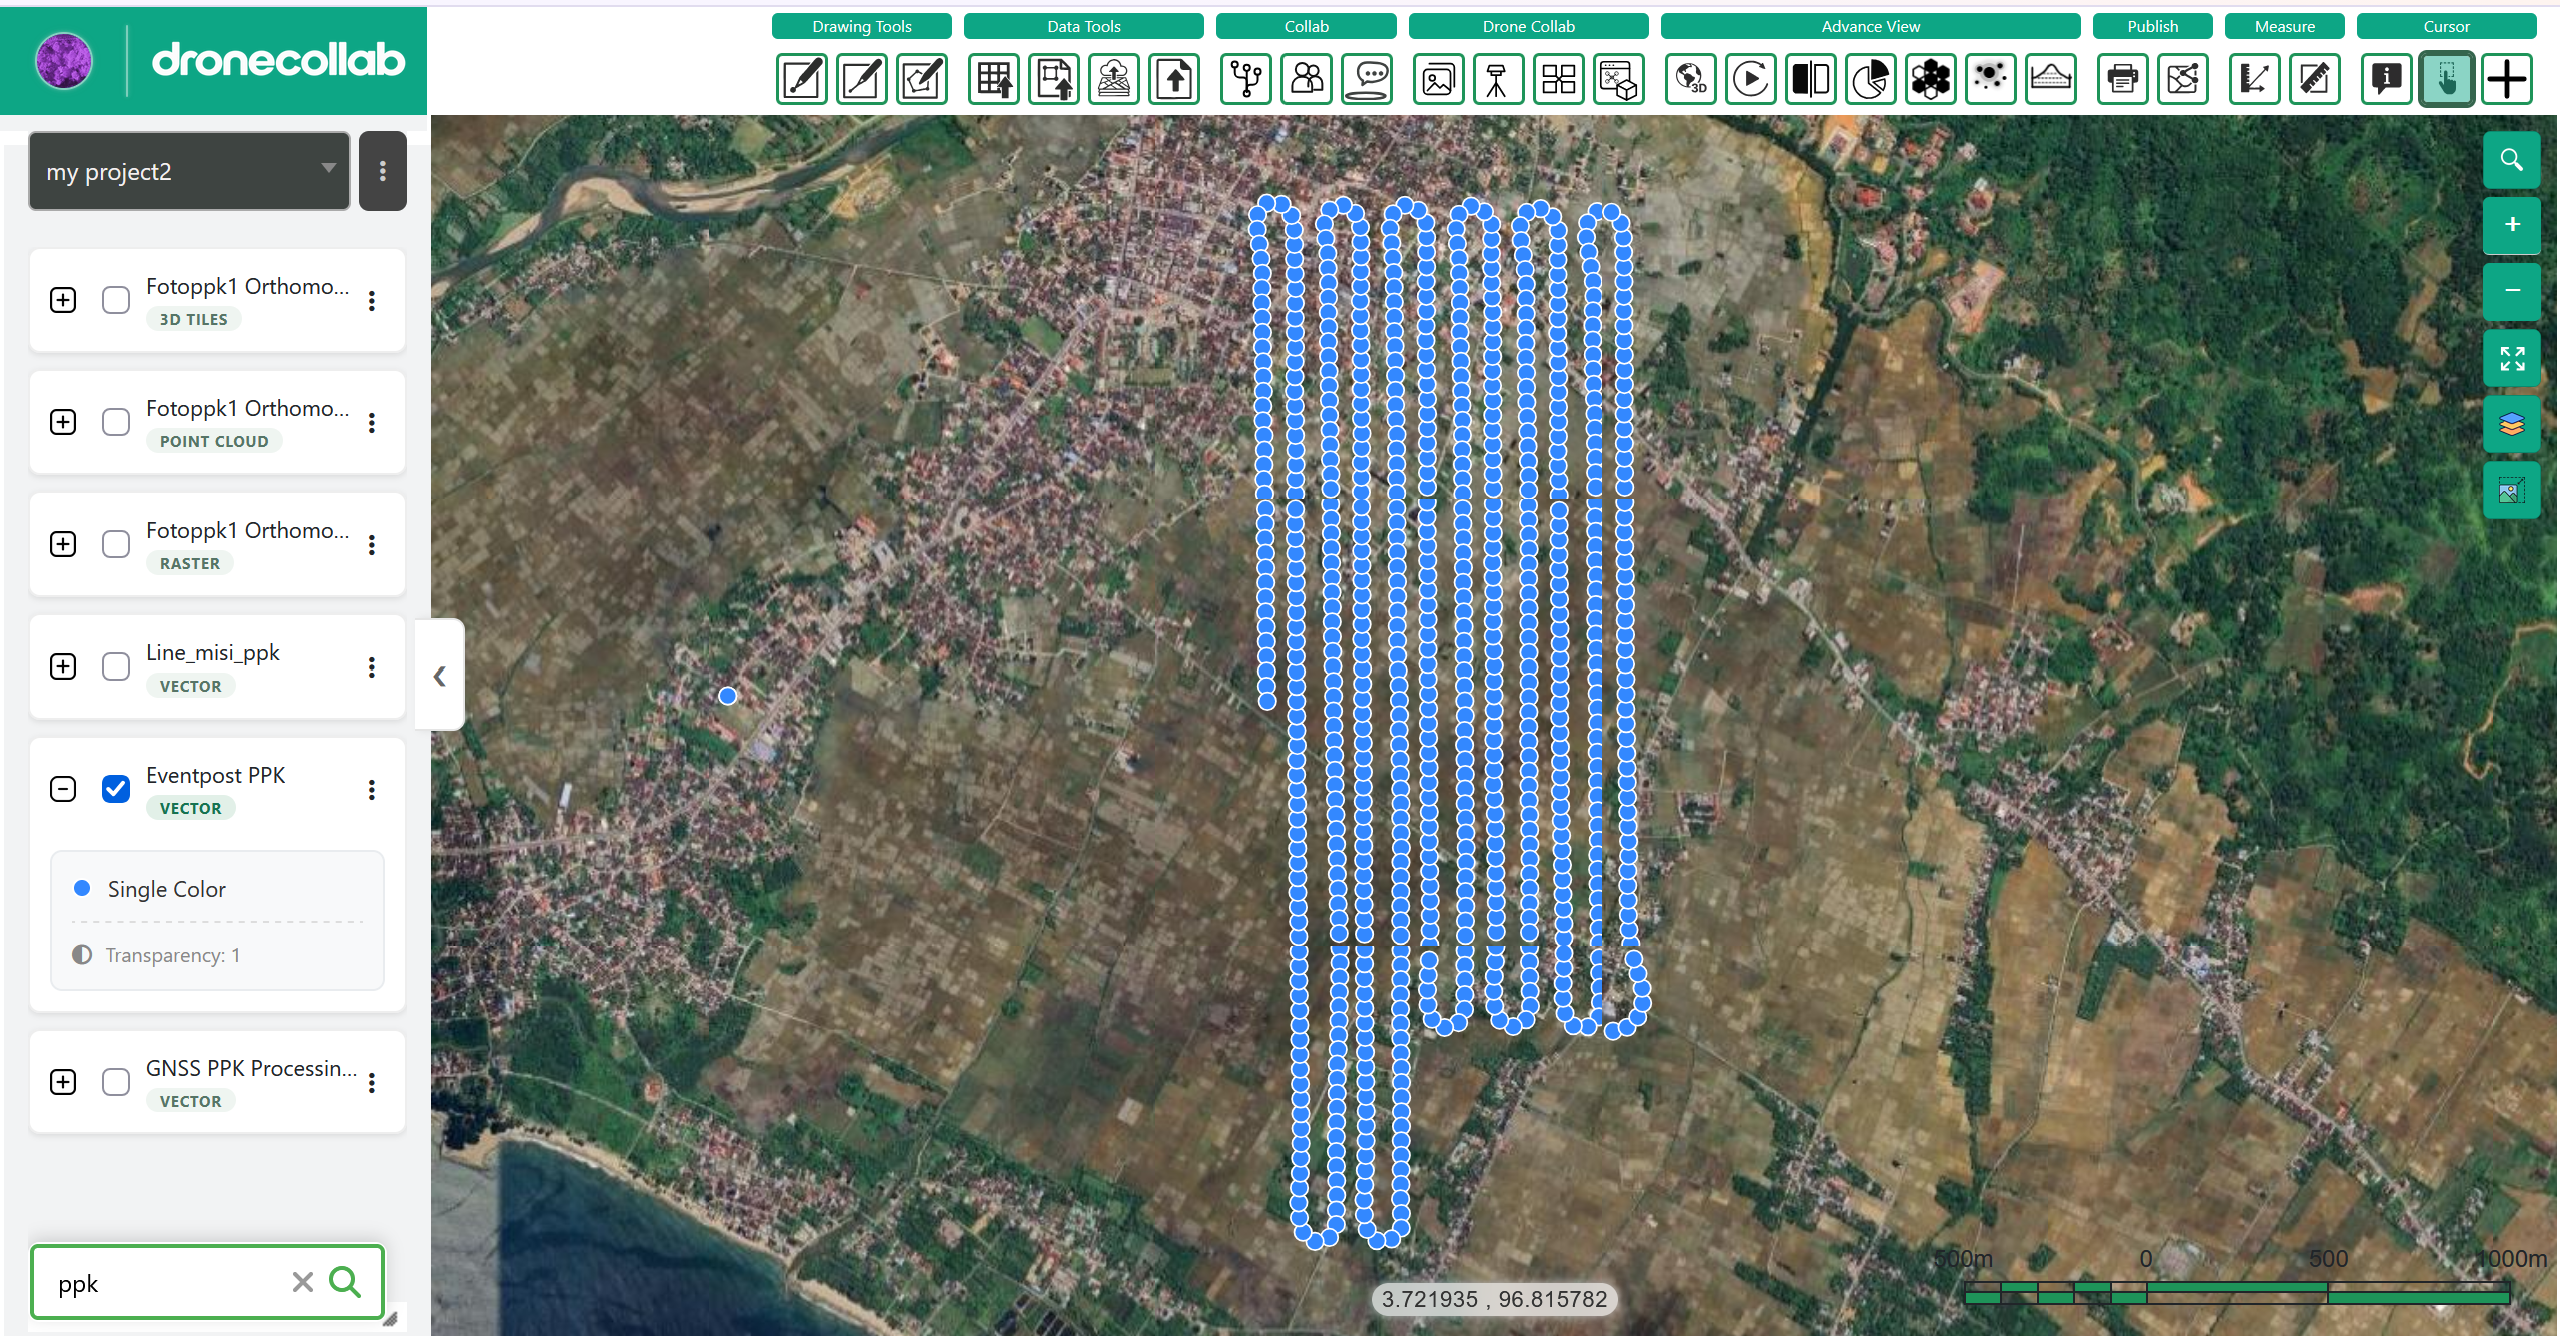
In My Processing, inspect FIX/FLOAT, accepted precision, epochs and event counts. View the resulting Layers and download the report and available POS, CSV or GeoJSON. EventPost camera positions require recorded trigger events.
Full form: fields, choices and explanations
My Processing · Report / Layers
Precision Acceptance defaults to 0.10 m (range 0.01–1.00 m) and flags estimated 3-D sigma. It is not guaranteed field accuracy and does not convert FLOAT to FIX; RTKLIB FIX remains q=1. Check the report, FIX rate and warnings. Full trajectory epochs differ from camera-trigger EventPost positions.
| Field | Default / choices |
|---|---|
| RTKLIB Fixed / Float / Fix rate | Native ambiguity status; FIX q=1 |
| ≤ threshold / estimated 3-D sigma | Separate precision acceptance flag |
| POS / CSV / GeoJSON | Full trajectory, report and supported downloads |
| EventPost GeoJSON / CSV | Camera-trigger-only positions when receiver events exist |
Geotag the photos
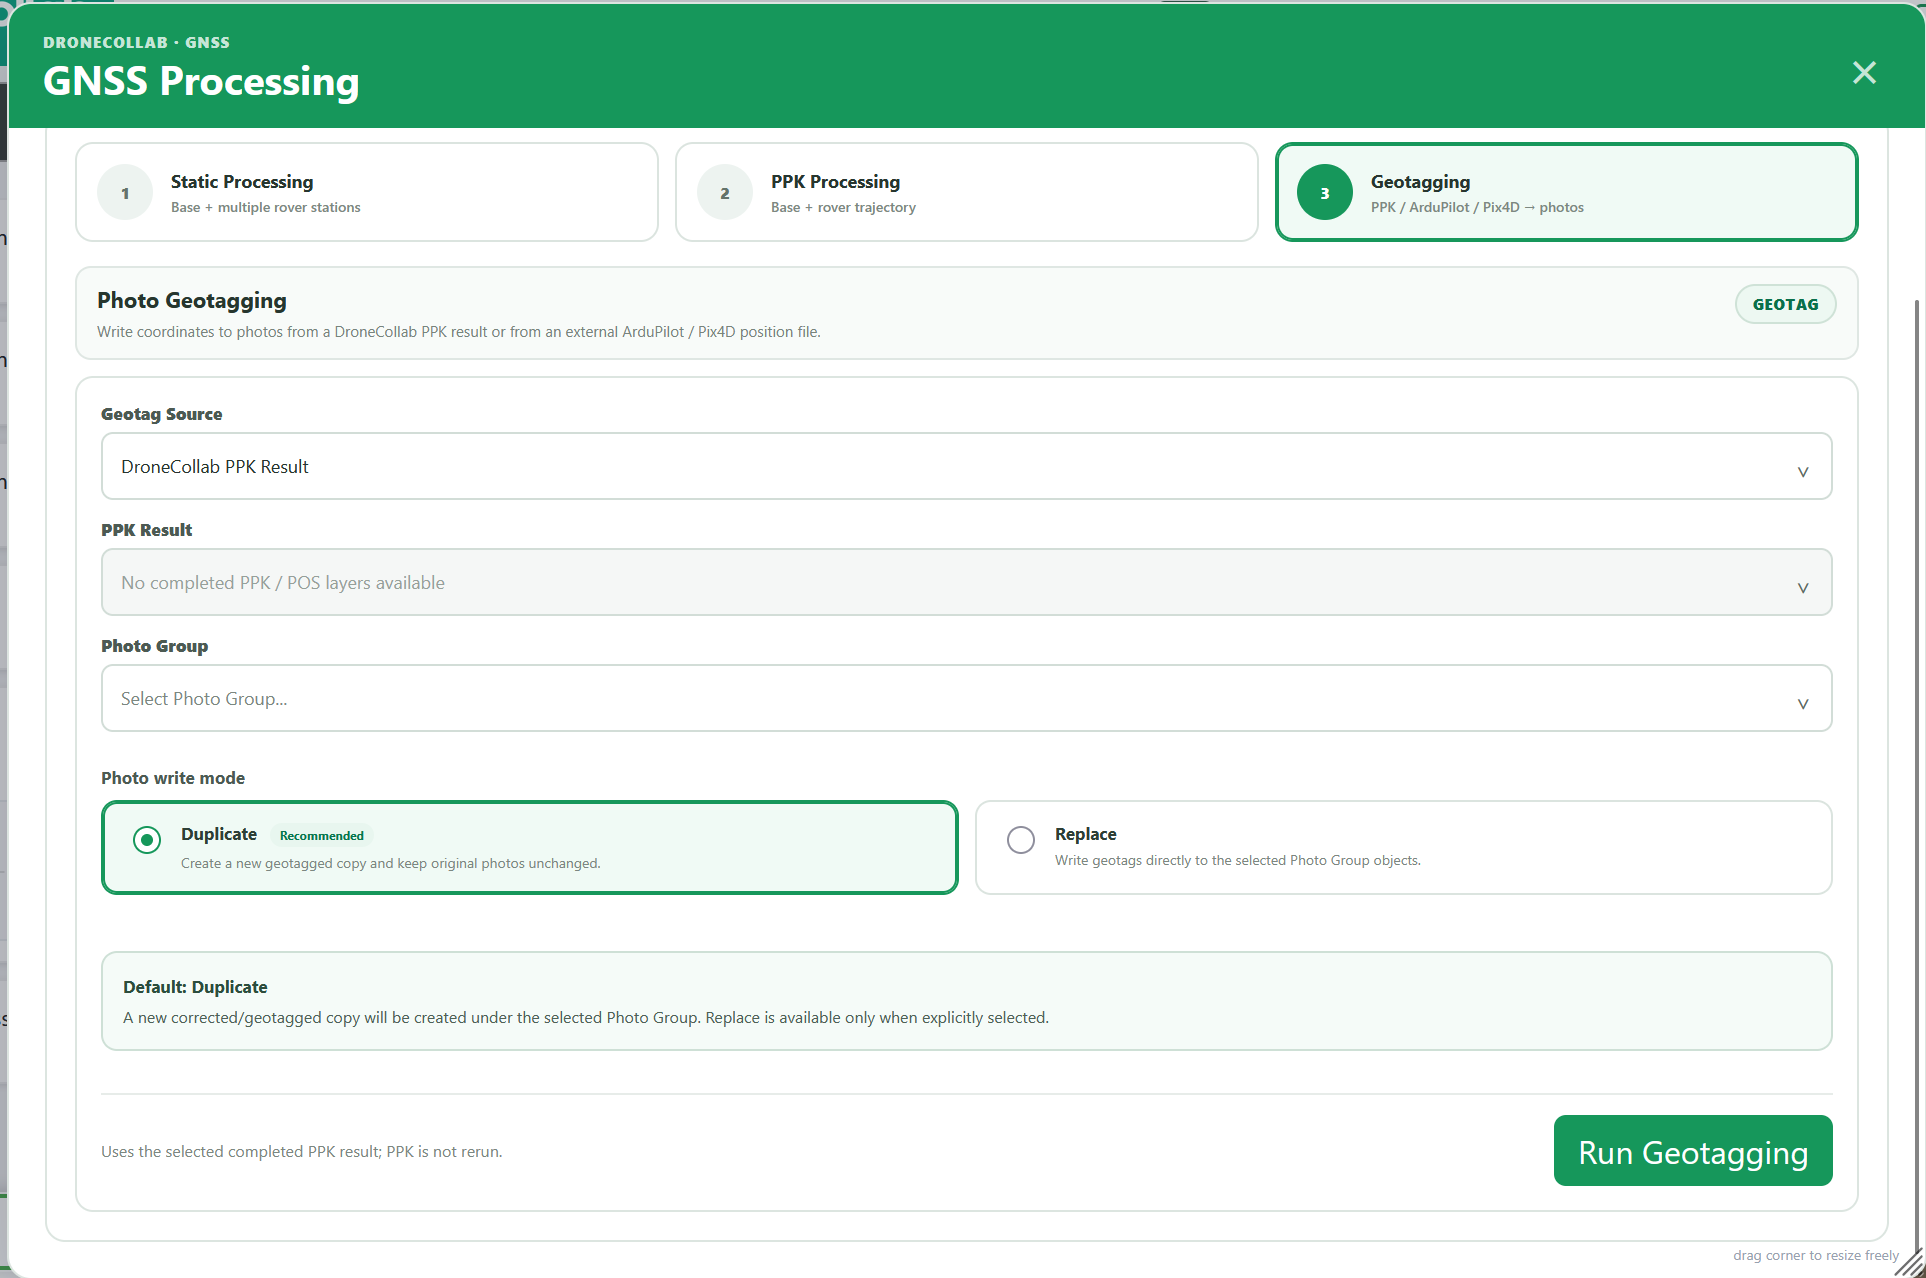
Upload photos through Photos first. Open Geotagging, select a completed PPK Result and the matching Photo Group. Keep Duplicate, click Run Geotagging and inspect the corrected copies before Ortho Processing.
Full form: fields, choices and explanations
Geotagging · Source / Photo Group
PPK Result lists completed PPK/POS layers in the active project. External sources instead accept ArduPilot .bin/.log/.tlog or Pix4D .csv/.txt/.xyz. Match the Photo Group to that flight and verify camera times or file names. No PPK rerun occurs. Duplicate keeps originals; Replace writes to the selected objects.
| Field | Default / choices |
|---|---|
| Geotag Source | DroneCollab PPK Result (default) / ArduPilot Flight Log / Pix4D Position / Geolocation File |
| PPK Result | Completed PPK / POS layer; shown for PPK source |
| ArduPilot Flight Log | Shown for ArduPilot; .bin / .log / .tlog |
| Pix4D Position / Geolocation Data | Shown for Pix4D; .csv / .txt / .xyz |
| Photo Group | Photos from the same flight, uploaded in the active project |
| Photo write mode | Duplicate (default) / Replace |
| Run Geotagging | My Processing; writes photo GPS; no PPK rerun |
If a dropdown is empty, confirm the active project, completed job and available layers or photo groups. If a job fails, inspect its message and navigation inputs. If EventPost is empty, verify receiver trigger events. After geotagging, verify sample photo coordinates and use the corrected group in Basic Processing.
Follow the steps → Basic Processing